Build a humanoid, teach it to walk
Course guide and project materials for 2026-2 Actuation and Sensing Mechanism Design for Robots (001).
eTL is the official channel. Course notices, homework, and presentation submissions are handled on eTL. This site is a guide and materials portal. If anything here conflicts with eTL, follow eTL.
The project
Over the semester you will:
- Assemble a bipedal humanoid robot, a modified version of the open-source Berkeley Humanoid Lite.
- Model the robot and its actuators so it can be simulated.
- Train a walking policy with reinforcement learning in simulation.
- Transfer the policy from simulation to the real robot (sim-to-real).
- Carry out a task of your team’s own design.
Where to find things
| Section | What’s inside |
|---|---|
| Start Here | Course introduction and the Berkeley Humanoid Lite reference |
| Robot Hardware | Bill of materials, actuator assembly, motor driver, USB-to-CAN adapter, body system, low-level software, full robot assembly |
| From CAD to Robot | Onshape CAD and converting it to a robot description |
| Simulation and Learning | Robot model (MuJoCo / mjlab), actuator modeling, Isaac Sim and Isaac Lab, mjlab, real robot safety |
| References | References for the course project |
| Downloads and Versions | Released files (part files and the robot model) and their version history |
| Help | Where to ask questions and how to report problems with this site |
Material status
Materials are published as the course progresses. Sections marked Partly available are usable but still being expanded.
| Section | Status |
|---|---|
| Start Here | Available |
| Robot Hardware | Available |
| From CAD to Robot | Available |
| Simulation and Learning | Available |
| References | Partly available |
Gallery
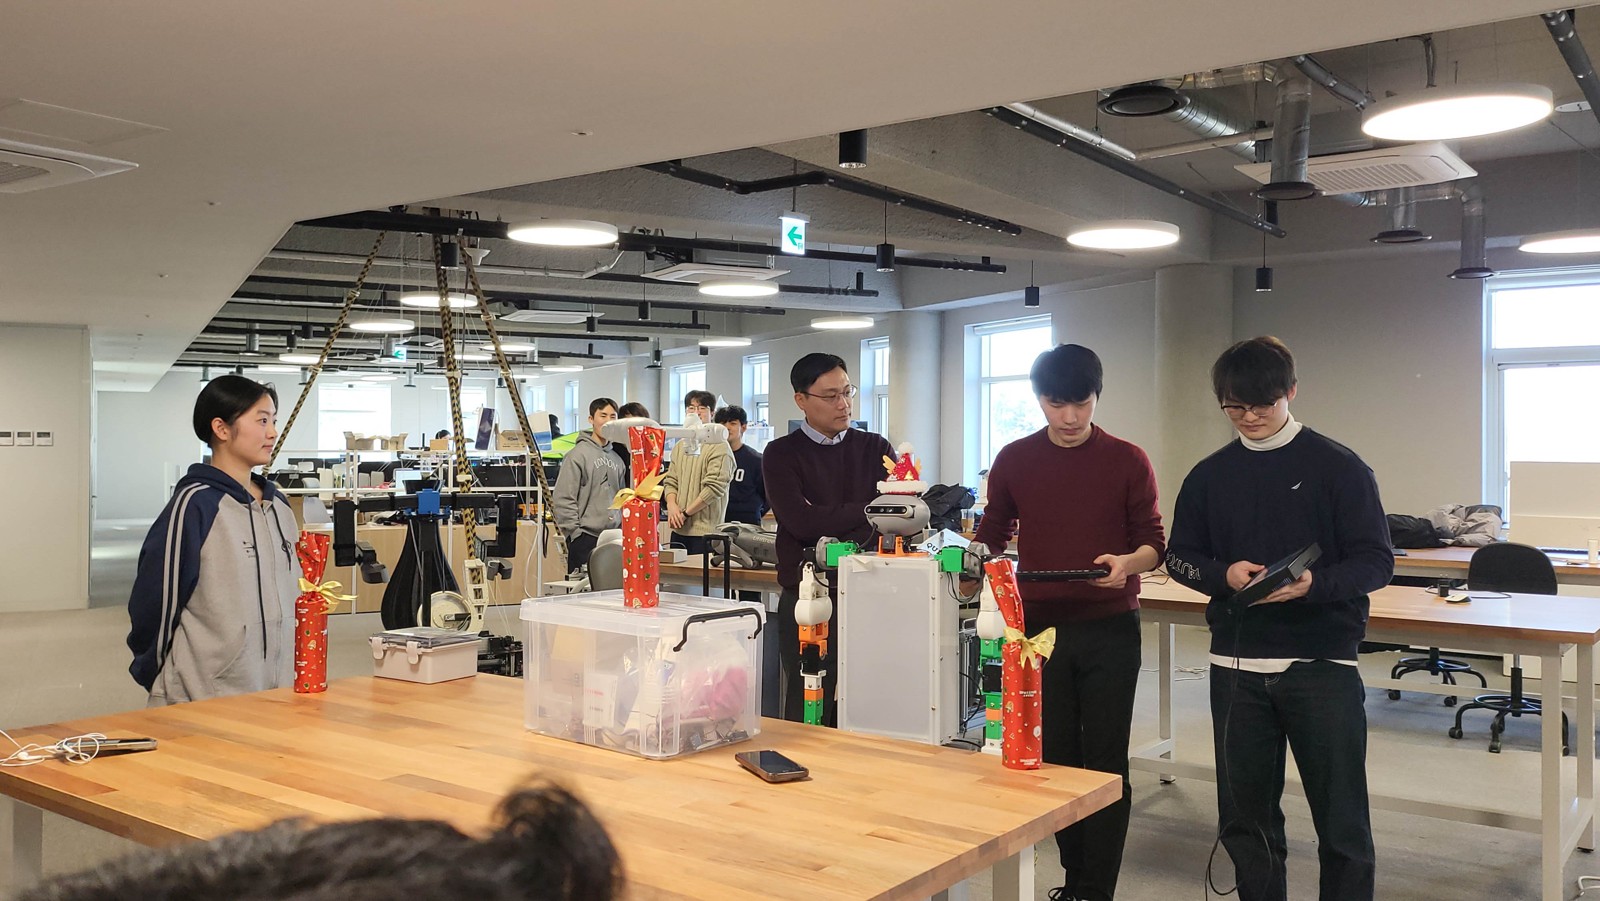
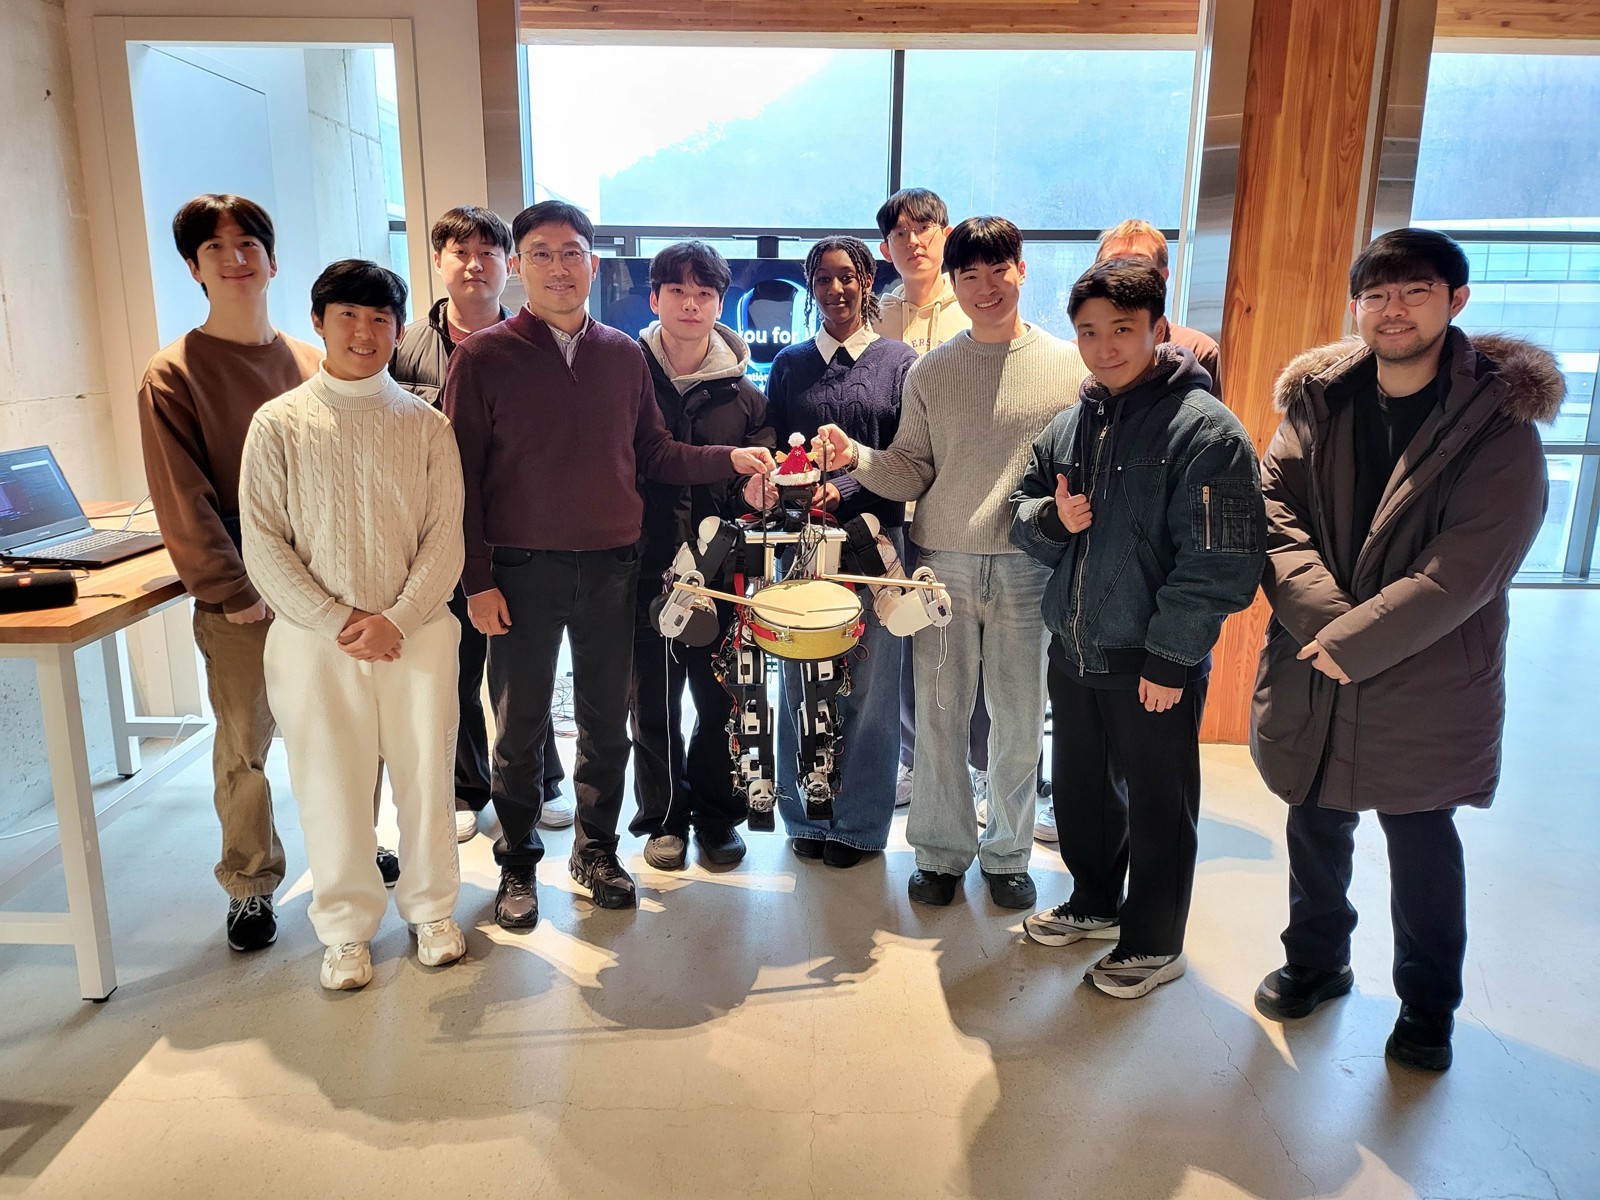
The humanoid robots built by previous classes of this course.