Onshape-to-Robot Guide
onshape-to-robot is a tool that exports a robot designed in Onshape to robot description formats that simulators can load, such as URDF, SDF, and MuJoCo (MJCF).
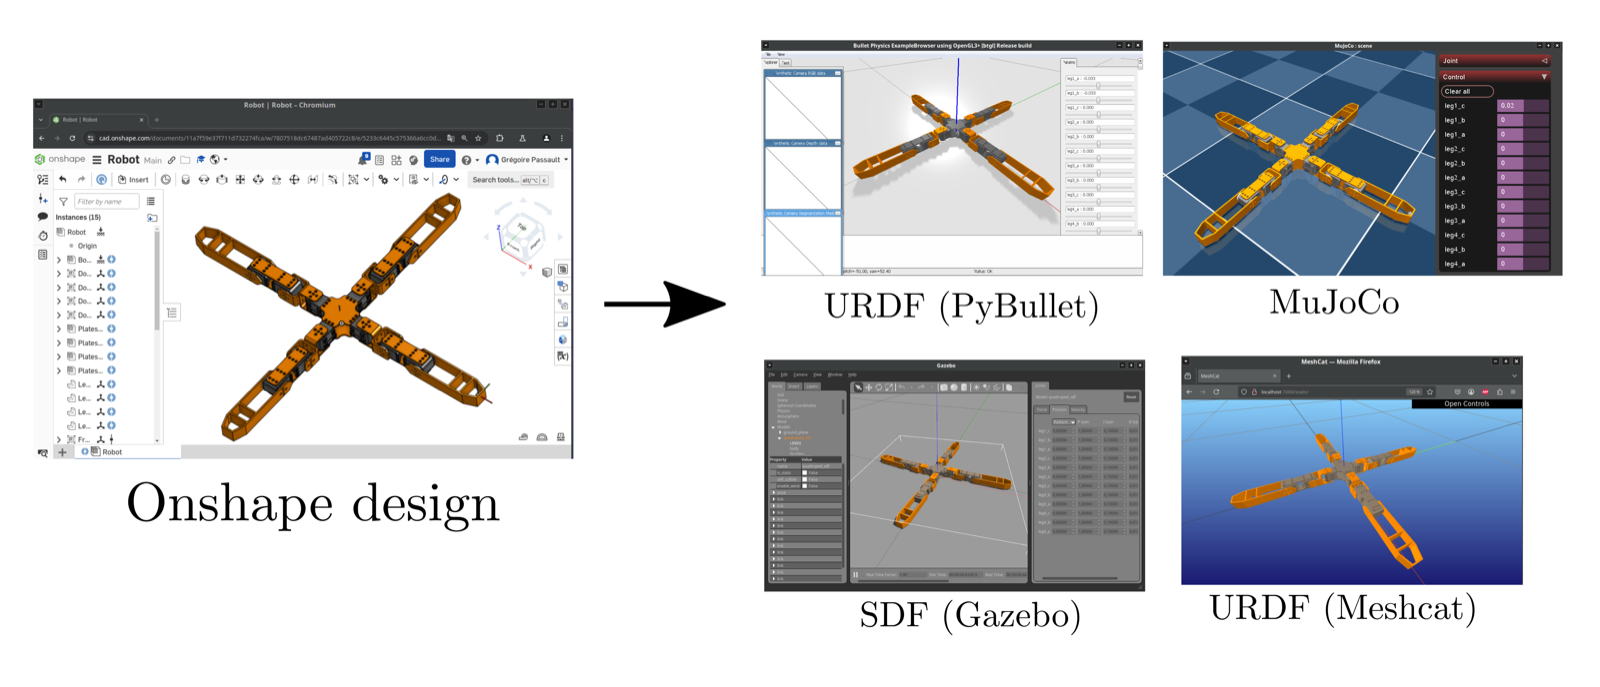
From an Onshape design to URDF, SDF, and MuJoCo (image: onshape-to-robot documentation)
Official resources
Example: Berkeley Humanoid Lite
Berkeley Humanoid Lite uses onshape-to-robot to generate its robot description files. Their scripts are a very useful example of how to use onshape-to-robot in practice from a Python program:
Berkeley Humanoid Lite Assets: scripts (GitHub)
| Script | What it does |
|---|---|
export_onshape_to_urdf.py |
Exports the Onshape CAD model to URDF |
export_onshape_to_mjcf.py |
Exports the Onshape CAD model to MJCF (MuJoCo) |
convert_urdf_to_usd.py |
Converts the URDF to USD |
The export scripts run onshape-to-robot with a config.json file that describes the export settings.